whoami
Marcin Wysocki.
 photo
assets/me.jpg
machinekind.ai
photo assets/cool/droids.jpg
 assets/cool/k2so.jpg
 assets/cool/ironman.jpg
 assets/cool/bb8.jpg
 assets/real/industrial.jpg
 assets/real/cnc.jpg
 assets/real/roomba.jpg
 assets/real/thermomix.jpg
 assets/now/atlas.jpg
 assets/now/optimus.jpg
 assets/now/g1.jpg
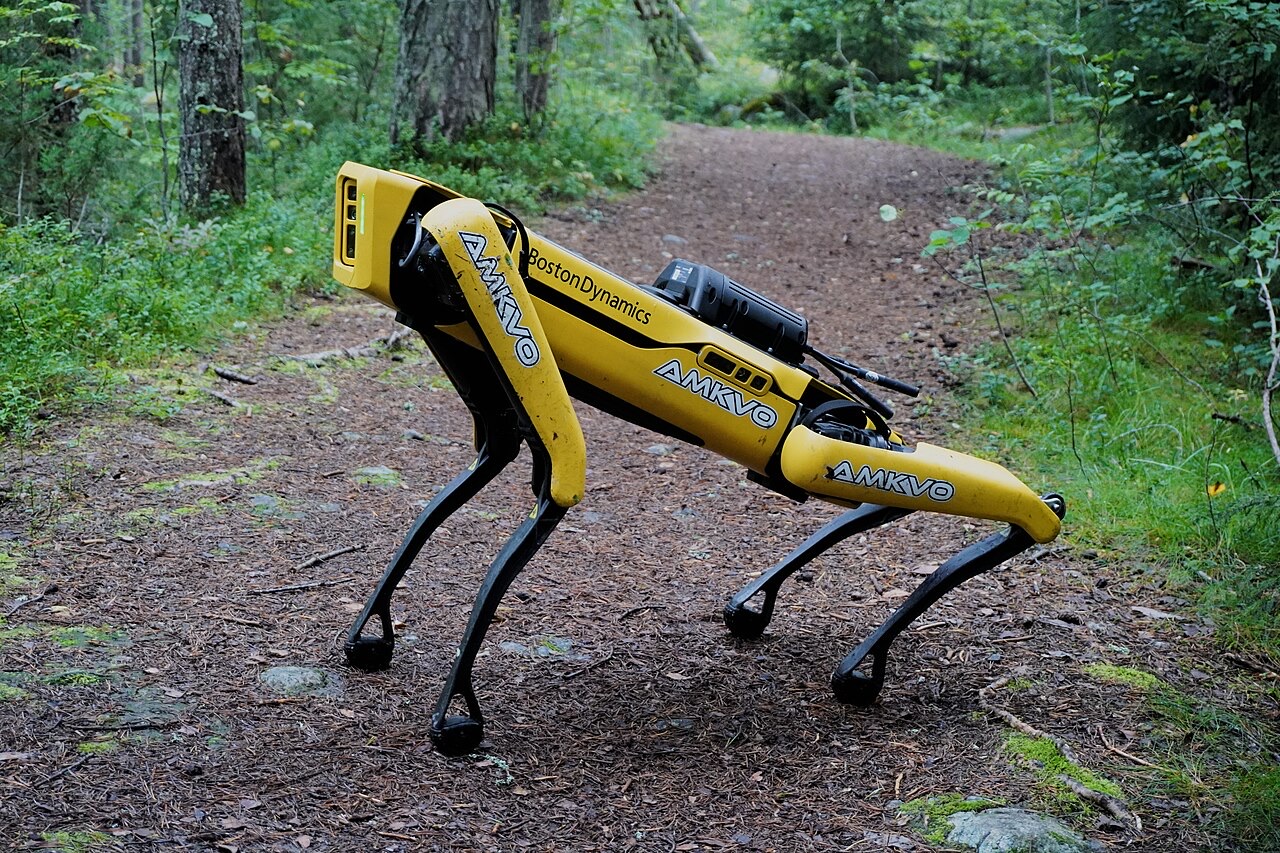 assets/now/spot.jpg
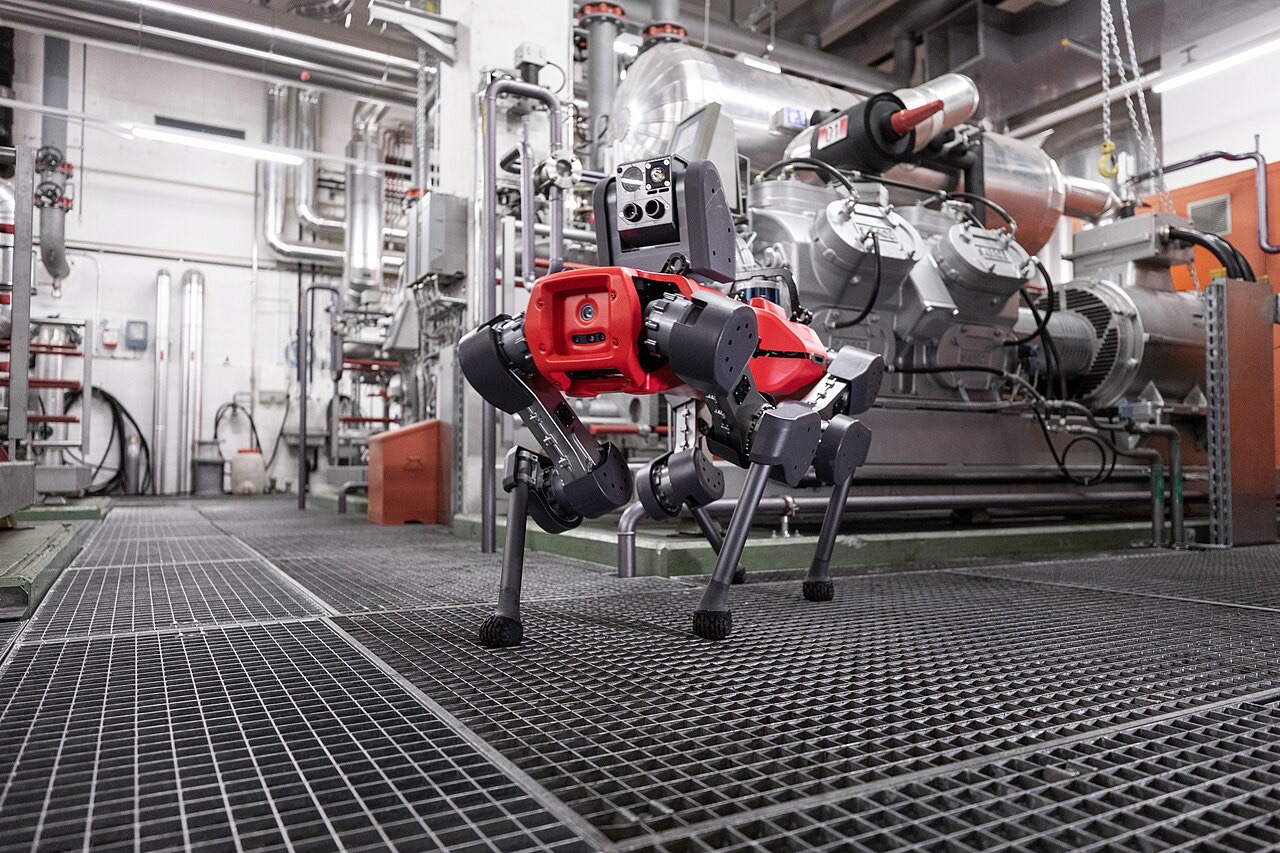 assets/now/anymal.jpg
| model | fastest setting | answers per second | thinking hard |
|---|---|---|---|
| Gemini 4 Argon | – | – | 41 s |
| Claude Fable 5.2 | 8.5 s | 0.12 Hz | 267 s |
| Claude Opus 5.5 | 4.8 s | 0.21 Hz | 343 s |
| GPT-6 Astra | 3.6 s | 0.27 Hz | 229 s |
| Qwen3-VL 30B the one on Wojtek | 2.6 s | 0.38 Hz | – |
| Gemma 4 26B | 1.7 s | 0.60 Hz | 27 s |
| Nemotron Nano 12B VL | 1.5 s | 0.66 Hz | – |
| Qwen3 Omni 30B | 1.2 s | 0.86 Hz | 26 s |
| Llama 4 Scout | 1.1 s | 0.88 Hz | – |
| Phi-4 Multimodal | 0.42 s | 2.4 Hz | – |
| Wojtek’s walking policy | 0.02 s | 50 Hz | – |
| model | thinks | one thought gives | moves | the fast part is |
|---|---|---|---|---|
| OpenVLA 2024 | 6 Hz | 1 move | 6 Hz | none |
| GR00T N1 2025 | 10 Hz | 16 moves | 120 Hz | replay of the batch |
| Gemini Robotics 2025 | ~4 Hz | a batch of moves | 50 Hz | replay of the batch |
| π0.5 2025 | – | 50 moves | 50 Hz | replay of the batch |
| Helix 2025 | 7–9 Hz | a goal, not moves | 200 Hz | a 2nd network that keeps looking |
| model | robot | how the body is driven | their headline |
|---|---|---|---|
| Gemini Robotics 2.5 Google · Nov 2026 | Apollo 2 | a VLA for the whole body, 22-DoF hands | 96% · factory kitting pilot, arms + hands |
| Helix 02 Figure · Jan 2026 | Figure 03 | three networks: planner · joints at 200 Hz · balance at 1 kHz | 4 min, 61 steps, no resets |
| GR00T N1.7 NVIDIA · 2026 | Unitree G1 | the VLA writes tokens, a learned controller moves the joints | open weights · 28 Hz on a Jetson |
| task | status | in one line |
|---|---|---|
| reasoning | slow | good plans, a few seconds each |
| navigation | glue | maps and planners drive; AI only names the goal |
| locomotion | real | deployed, cheap, boring in the best way |
| manipulation | pilot | first factory pilots; narrow, hungry for data |
| world models, WAMs | lab | on real robots in the lab; first product promised for 2026 |